When You Add Cameras to a Semiconductor or PCB Line, the Interface Rewrites the Optics
OPTICS
Use a 5,120 px camera to put a 10 μm defect into three pixels and each frame becomes 26.2 MB, which 1 GigE cannot send faster than 4.8 frames per second.
Taking a 10 μm defect in fine PCB circuitry as the reference, I calculated in one chain the pixel count, the data per frame, the interface ceiling, and the conditions that smaller pixels leave on the lens and depth of field.
About 10 min read
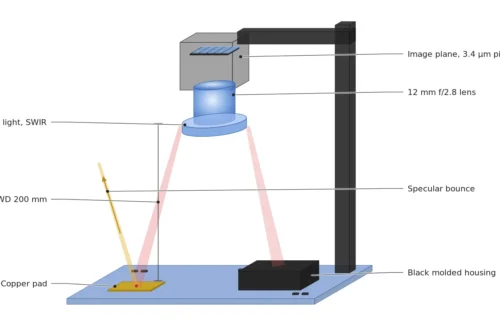
The target is a fine-circuit section of a PCB. Copper traces are smooth and throw light back in one direction like a mirror, while the substrate between them scatters light back, so brightness differs widely under the same lighting. The defects to find are protrusions and nicks 10 μm wide at the trace edges. On strongly glossy copper, a small change in lighting angle flips the contrast, so the calculation starts by writing down this surface condition.
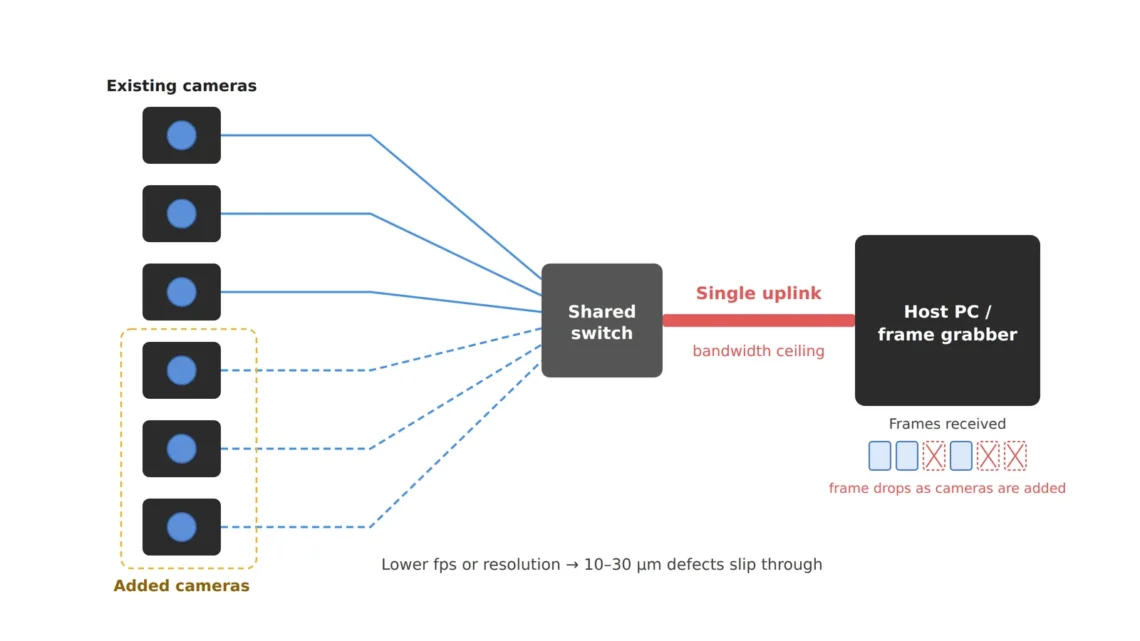
The smaller the defect, the more pixels the camera needs, and the more pixels, the larger each frame. If the interface1 cannot carry all that data, you end up lowering the frame rate or cutting resolution, and at that moment the 10 μm defect slips through the inspection net. That is why a decision to add cameras reopens the lens and lighting design too.
When I review a camera expansion, I start from the defect size and calculate in one chain the data per frame, the interface ceiling, and the conditions the pixel size imposes on the lens. Change any one cell and the others move with it.
A 10 μm defect narrows the frame to 17 mm
My rule is that the smallest defect spans at least three pixels. For a 10 μm defect, one pixel on the object must be 3.33 μm or less, and assuming a camera of 5,120 × 5,120 px with 2.5 μm pixels, the field of view2 narrows to 17.1 mm. Covering a 48 mm wide section at once takes three cameras with 1 mm of overlap at each seam, and those three send data at the same time.
The data per frame, the frame size3, is about 26.2 MB for 5,120 × 5,120 px in 8-bit monochrome. Shooting 10 frames per second means one camera sends 262 MB/s, and three send 786 MB/s. That number is the starting point for choosing the interface. If the defect shrinks by half, the pixels needed for the same view double in each direction and the data quadruples.
The interface ceiling sets the frame rate
The theoretical ceiling of 1 GigE is 1,000 Mbit/s divided by 8, or 125 MB/s, so it can send a 26.2 MB frame only up to 4.8 times per second. The ceiling is the speed. In practice packet headers trim that ceiling a little more. 10 GigE has a theoretical ceiling of 1,250 MB/s and supports the same camera up to 47.7 frames per second, and gathering three cameras on one link uses 786 MB/s, or 63 %. CXP-12 in CoaXPress4 2.0 carries 12.5 Gbit/s on one coaxial cable, which is 1,250 MB/s per cable after removing the 8b/10b encoding5.
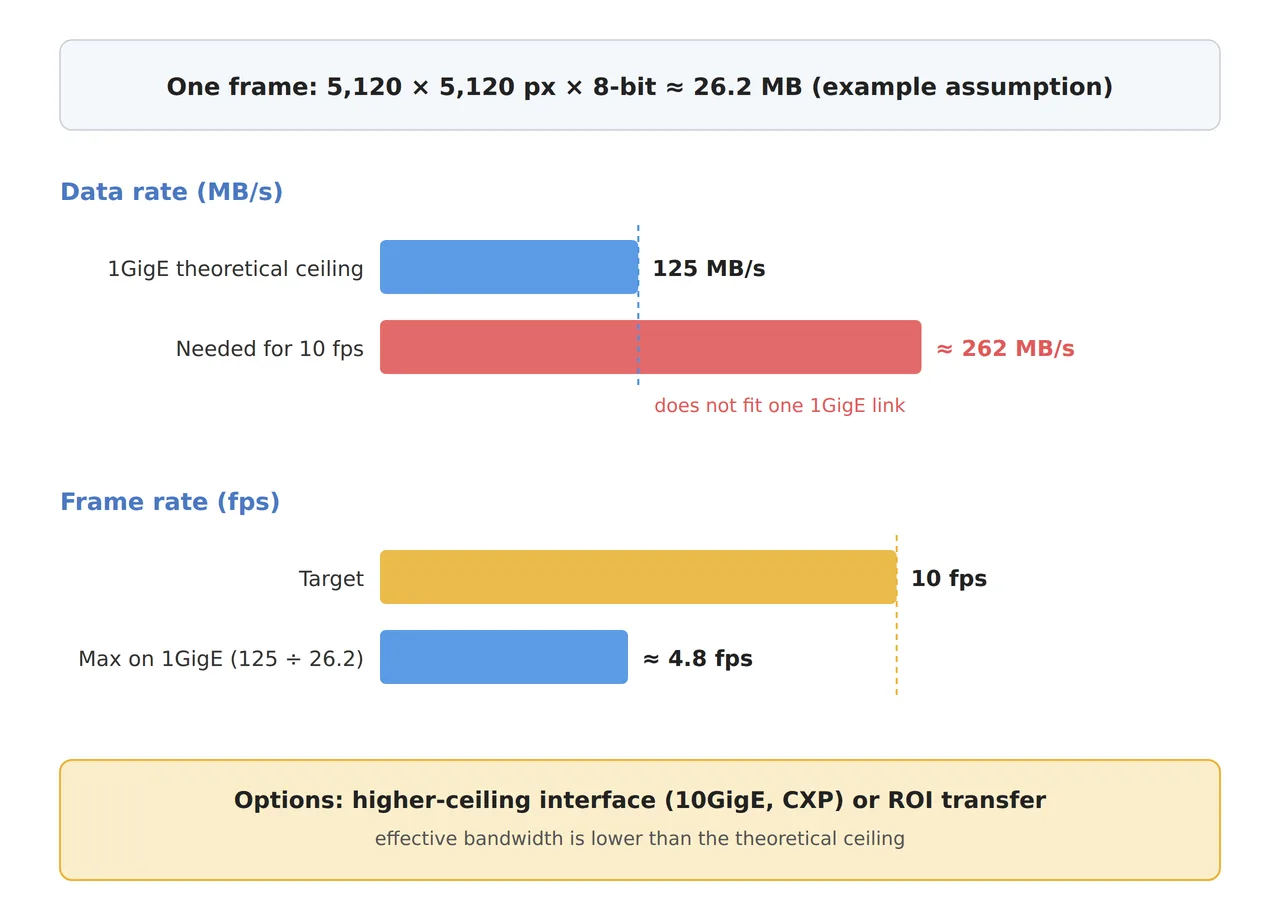
The chart shows the same calculation from two directions, data rate and frame rate. The 262 MB/s needed for the 10-frame target is more than twice the 1 GigE ceiling, so the moment this camera is connected to 1 GigE, it cannot reach even half the target.
Common belief
Adding cameras raises the inspection speed in proportion.
Tie three cameras to one 1 GigE link
Three 26.2 MB cameras share 125 MB/s and fall to about 1.6 frames per second each, so the gain from the extra cameras disappears in the link.
Each interface also has its own practical cable length. CXP-12 is documented at about 30 m as a practical length on RG-6 class coax, so if the distance between the camera and the PC exceeds that, the PC position has to be decided again. Whether there is room to place the PC inside the inspection machine body is answered by the machine drawing.
Region of interest is the knob that cuts the data
Before changing the interface, I count how many rows of the frame are actually used for judgment. If the section where traces run is a band one fifth of the frame, sending only that band as a region of interest6 cuts each frame to 5.24 MB, and even 1 GigE delivers 23.8 frames per second. It is a way to clear the bottleneck with one camera setting and no new interface hardware. It costs nothing.
The region of interest has its price too. Defects outside the band are never seen, so it works only when the places where defects can occur are fixed by the drawing. On a board with circuitry across the whole frame, the data cannot be cut, and the remaining choice is an interface with a higher ceiling.
Smaller pixels change the lens and the depth of field
Carrying all the data does not finish the optics. A 2.5 μm pixel means telling apart 200 line pairs within 1 mm on the sensor, and the pixel count means something only if the lens delivers that much resolution. At a magnification7 of 0.75, a 12.8 mm wide sensor seeing 17.1 mm, there is also little room to stop down. Keeping the diffraction8 blur spot within two pixels, 5 μm, puts the limit near f/2.
26.2MB
Data per frame for a 5,120 × 5,120 px, 8-bit monochrome camera
4.8fps
Frames per second that camera can send at the 125 MB/s theoretical ceiling of 1 GigE
0.06mm
Depth of field at a magnification of 0.75, f/2 and a 5 μm circle of confusion
A bright aperture cuts the depth of field9. With the circle of confusion set to two pixels, the depth of field is about 0.06 mm at f/2 and 0.09 mm even at f/2.8. If board warpage within the 17.1 mm view exceeds a few tens of μm, part of the frame goes out of focus, so focus adjustment that follows the height, or flattening such as vacuum hold-down, has to go into the design. Warpage is a spec item too. If it were my setup, I would build height-following focus into any board whose warpage within the view exceeds 30 μm from the start. One decision to change the camera ends up redrawing the fixture and the focus mechanism.
Inspection conditions redrawn for each interface
Redraw the table for the same 10 μm defect under three interface configurations, and you can see how the judgment conditions follow when the interface row changes. The view and magnification in the optics column are set by the defect size, so all three rows share them, and what changes is the frame rate and the region of interest.
| Configuration | ① Minimum defect size | ② Optical setup · WD | ③ Algorithm parameters · in plain words |
|---|---|---|---|
| 1 GigE, full frame | 10 μm = 3.0 px (3.33 μm/px) | 5,120 px with 2.5 μm pixels, magnification 0.75, 17.1 mm view, f/2 (depth of field about 0.06 mm), about 117 mm from lens center to board with a 50 mm lens, coaxial light | 4.8 frames per second is the ceiling. A 10-frame target cannot work |
| 1 GigE, region-of-interest band | 10 μm = 3.0 px | Same optics, sending only a 5,120 × 1,024 px band | 23.8 frames per second. Defects outside the band are never seen, so use it only when defect positions are fixed by the drawing |
| 10 GigE or CXP-12 | 10 μm = 3.0 px | Same optics, 1,250 MB/s per link | 47.7 frames per second per camera, 63 % even with three on one link. Judge the full frame and retake warped sections with a low focus score |
Compared across the rows, the table shows that the defect size fixes the optics column while the interface sets the frame rate and the judgment area. On the other hand, for an inspection with one or two cameras where a few frames per second is enough, 1 GigE still has room to spare, and CXP earns its cost where a few cameras push a lot of data, such as ultra-fast line scan. Whether these conditions actually protect defect contrast on boards where copper gloss changes from lot to lot cannot be guaranteed before a sample test.
Fill this table before adding one more camera
The first thing I bring to a camera expansion meeting is a table with one row each for the defect size, the pixel size, the view, the data per frame, the interface ceiling, and the aperture with its depth of field. Changing one cell moves the rest, so choosing the camera spec sheet can wait until this table is filled in. If you are just starting, I recommend calculating 26.2 MB and 4.8 frames once by hand. Why a camera catalog lists different frame rates for different interfaces is inside that calculation.
With one person matching the interface and optics in a single table, reworking lenses and fixtures after an expansion becomes rare. From the purchasing side, interface hardware may look like a camera accessory, but that choice sets both the inspection speed and the lower limit of the defect size you can catch. This article explains technology and is not investment advice. See our Disclaimer.
Field Note
For a new setup on this section, I connect the 5,120 px camera to 1 GigE and raise the frame rate step by step through 4 and 5 frames per second, noting where frame drops begin. Watching whether drops start near the calculated 4.8 frames tells me how much the packet headers really take. At the same spot I focus on the four corners of the board to measure the height difference, and check that it fits within the 0.06 mm depth of field at f/2.
Field Checkpoints
Once you have confirmed in numbers where drops begin and how much the board height varies, check the expansion plan with the questions below.
- Is the WD of the lens model (about 117 mm from the lens center for a 50 mm lens) secured even after adding the coaxial light and the focus adjustment mechanism? (whether the light housing blocks the front of the lens)
- Does a 10 μm defect span three pixels or more? (3.33 μm per pixel or less; with 5,120 px, a view of 17.1 mm or less)
- Does data per frame × target frame rate × camera count fit within 80 % of the interface ceiling? (26.2 MB × 10 frames × 3 cameras = 786 MB/s)
- If you use region-of-interest transfer, did you fix by drawing where defects can occur? (whether you accept that defects outside the band are never seen)
- Is the lens rated to handle 2.5 μm pixels, and does the board warpage fit within the 0.06 mm depth of field at f/2? (if not, whether you added focus adjustment or flattening)
- Did you confirm with samples that defect contrast holds as the copper gloss changes? (whether you avoid concluding on glossy surfaces from calculation alone)
Frequently Asked Questions
Which should I pick, 10 GigE or CXP-12?
Both carry about 1,250 MB/s per link, so bandwidth alone does not decide it. Cable length and wiring method, receiving hardware such as a frame grabber10, and the standard the existing equipment uses make the choice. Either way, the principle of splitting cameras so that data per frame times frame rate stays within 80 % of the link ceiling is the same.
Can I keep the existing lens if I change the interface?
If only the interface changes and the camera sensor stays the same, the lens stays too. The issue comes when you switch to a camera with a different pixel count or pixel size to fit the interface ceiling. A different sensor size changes the magnification and the view, and the lens image circle and resolution class have to be checked again.
Glossary
- [1] Interface camera interface
The connection standard that sends the data a camera captures to the PC. GigE Vision and CoaXPress are examples. ↩ - [2] Field of view field of view, FOV
The area on the board that one camera frame covers. ↩ - [3] Frame size frame size
The amount of data in one frame. It is horizontal pixels × vertical pixels × bytes per pixel. ↩ - [4] CoaXPress CXP
A machine vision interface standard that sends camera data over coaxial cable. CXP-12 in version 2.0 carries 12.5 Gbit/s per cable. ↩ - [5] 8b/10b encoding 8b/10b encoding
A method that turns 8 bits of data into a 10-bit signal for sending. Only 80 % of the line rate carries actual data. ↩ - [6] Region of interest region of interest, ROI
The part of the frame cut out for sending or processing because judgment uses only that part. ↩ - [7] Magnification magnification
The size of the image on the sensor divided by the size of the object. Seeing 17.1 mm with a 12.8 mm wide sensor gives 0.75. ↩ - [8] Diffraction diffraction
Light spreading as it passes the lens opening. The more you stop down, the larger a point blurs. ↩ - [9] Depth of field depth of field, DOF
The depth over which things stay sharp in front of and behind the focus distance. It narrows as magnification rises and as the aperture gets brighter. ↩ - [10] Frame grabber frame grabber
A receiving card plugged into the PC to take in camera signals. CoaXPress cameras are received through a dedicated grabber. ↩
References
- Wikipedia, CoaXPress (CXP-12 in CoaXPress 2.0: 12.5 Gbit/s per coax, 8b/10b encoding, typical practical cable length of 30 m on Belden 1694A), accessed October 24, 2026
- Formulas: pixel size = view ÷ horizontal pixel count; frame size = width × height × bytes per pixel; maximum frame rate = link ceiling ÷ frame size; 1 GigE theoretical ceiling = 1,000 Mbit/s ÷ 8 = 125 MB/s; CXP-12 effective rate = 12.5 Gbit/s × 8/10 ÷ 8 = 1,250 MB/s; Nyquist = 1 ÷ (2 × pixel size); diffraction blur diameter ≈ 2.44 × λ × N × (1 + m); depth of field ≈ 2 × N × c × (1 + m) ÷ m²
- Assumed values: a 5,120 × 5,120 px camera with 2.5 μm pixels, 10 frames per second, a 48 mm section width, 1 mm overlap, a 50 mm lens, λ = 0.55 μm and a 5,120 × 1,024 px judgment band are assumptions for the worked example
Related reading — Camera Interface Bandwidth Determines Resolution · Why the PoE Network Card Sets the Limit on Your Optical Setup in a Multi-Camera Inspection Line · In PCB Inspection, the Lens Comes Before the AI

Noctvision
An engineer who has handled mechanical design and project management for production equipment since 2005. Here I work through the cameras, lenses and lighting that go into equipment with formulas and public data, and record the assumptions and sources alongside the numbers.


You May Also Like
Can One Focus Plane Keep Parts of Every Height Sharp?
When Height Varies, F7.1 Beats F16 on a Telecentric Lens