What Changes in Vision Inspection When Logistics Automation Moves Into the Front End
EDGE AI
The longer the transport run, the closer an inspection point has to sit behind the motion that creates the error, and that point succeeds or fails on whether the worst-case latency fits inside the stop window.
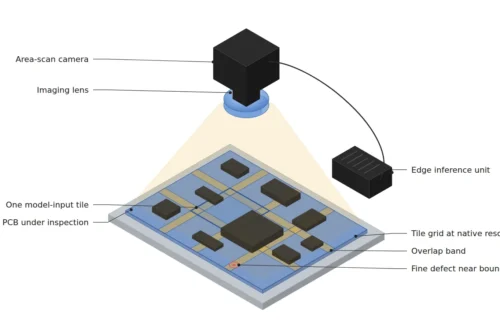
Taking a camera at a transport handoff that catches 50 μm chipping on a wafer edge and ±100 μm position drift, I calculated the resolution, the WD and the latency budget.
About 10 min read
At a transport handoff the camera sees two kinds of surface. The top of a wafer is close to a mirror, so light bounces off at the angle it came in, while the resin surface of the carrier holding the wafers is matte and scatters light in all directions. On the mirror-like face a slightly shifted lighting angle blows the frame out white or drops it to black, and on the matte face edges blur. The things to find are chipping1 on the wafer edge and position drift against a reference mark.
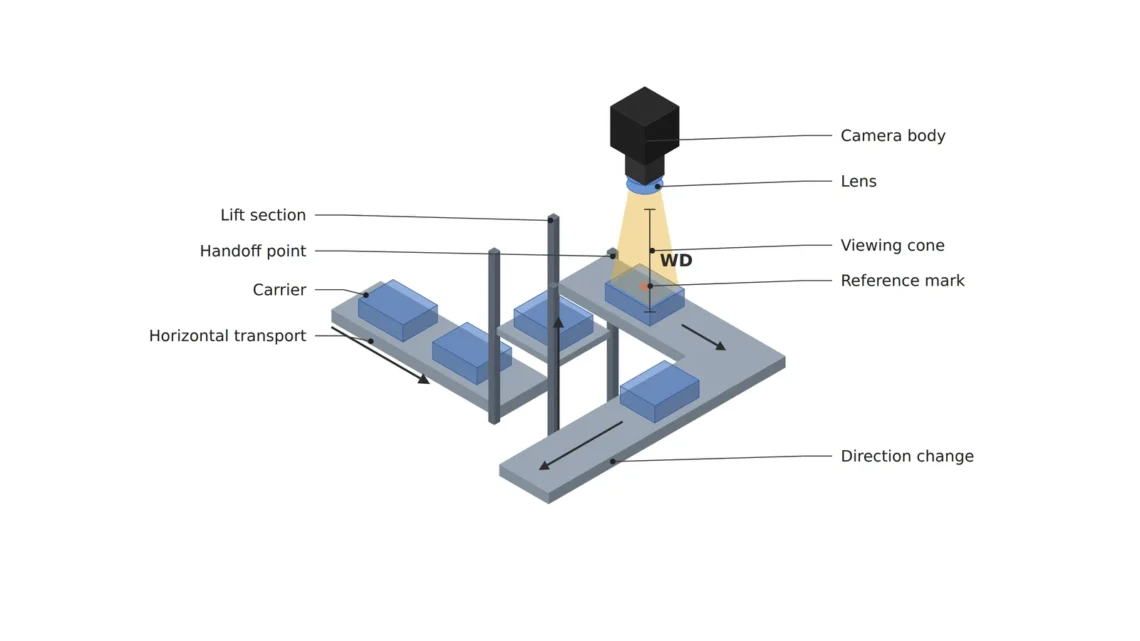
As logistics automation reaches deep into the front end through stockers, lifters and the overhead transport known as OHT2, transport distances and direction changes multiply. Small alignment errors and edge damage from contact or vibration in transit do not show where they form and appear only as yield numbers several steps later. While the cause is traced backward, wafers that took the same transport route keep moving on to the next process.
So vision checkpoints go onto the transport route. Where to put them, how large to make one pixel, and whether the decision can finish within the short window while transport is stopped are calculated in turn. The speed and stop control of the transport mechanism itself need a separate review.
Errors show up several steps after they form
Alignment errors tend to form in motions that change direction or height. At the moment the direction of acceleration changes, a slight slip can creep in between the wafer and its support. Yet the result is not visible where the error forms and appears only as a yield drop several steps later, so a checkpoint goes where the error first becomes visible, right after a lift or a direction change ends.
The time to find a cause depends on where the inspection points are more than on how many there are. With a camera only at final inspection, there is no clue to which section produced the drift, but measuring the same reference mark at every handoff3 turns the section where the drift jumped into a number. Cameras on every section lengthen stop time, so it is realistic to start by picking the sections where vibration and direction changes concentrate. I would put the first camera at the end of the section with the most direction changes on the route. The count comes after that.
One pixel of 14.7 μm sees chipping and drift together
Assume an edge chipping criterion of 50 μm and a position tolerance of ±100 μm. With a 2,448 × 2,048 px 5 MP camera of 3.45 μm pixels covering a field of view 36 mm wide, the resolution4 is 36 mm ÷ 2,448 = 14.7 μm/px. A 50 μm chip spans 3.4 pixels, and the ±100 μm tolerance is ±6.8 pixels.
By my standard, chipping has to span three pixels or more before I trust it as a blob, while position is measured finer than one pixel by locating the edge at subpixel5 level. Assuming an edge repeatability of 0.1 pixel gives 1.47 μm, plenty inside a ±100 μm tolerance. That 0.1 pixel, though, holds only while the edge is crisp, so how the lighting stands the edge up decides the number. On a near-mirror wafer face, bring in a low-angle bar light at a slant so the outside of the edge goes dark and the inside bright, or, where there is room to light from behind, make a silhouette with a backlight. Seeing scratches on the top face as well takes coaxial light, and doing both with one camera means switching the lights in turn. When a mirror-like face and a matte carrier share one frame, where to set the exposure becomes a split decision, so the result of that combination cannot be guaranteed before a sample test.
At the same field of view, WD grows with focal length
Installation space in a transport section is tight. Choosing a lens by resolution alone leads to lenses running into the mechanism, so calculate the distance from the lens tip to the target, the WD6, at the same time. With a 36 mm field of view and an 8.45 mm wide sensor, the magnification is 0.235, and in the thin-lens approximation the WD is the focal length times (1 + 1 ÷ magnification). That is 131.6 mm with a 25 mm lens, 184.2 mm with a 35 mm lens and 263.1 mm with a 50 mm lens.
131.6mm
WD of a 25 mm lens (36 mm FOV, thin-lens approximation)
184.2mm
WD of a 35 mm lens
263.1mm
WD of a 50 mm lens
At the same field of view, WD grows in proportion to the focal length. When clearance between mechanism and lens runs short, there is a way to step back without changing the field of view by moving to a longer lens. In exchange the lens gets longer and heavier, and if the light rides beside the camera it moves away by as much, so the light output gets checked too. I would draw a cylinder 184 mm long from the lens tip to the target on the mechanical drawing and keep other parts out of it. How to reserve this space at the mechanical design stage is written up separately in the camera installation space article.
A 200 ms stop window has to hold the worst case
Exposure, transfer, inference and the decision signal all have to finish inside the short window while transport is stopped, or the cycle time7 grows. Assume a 200 ms stop window and fill in numbers. With a 1 ms exposure, one 5 MP 8-bit frame of 5.01 MB sent at an effective 115 MB/s over Gigabit Ethernet takes 43.6 ms; with inference averaging 35 ms and the decision signal averaging 5 ms, the average total is 84.6 ms. The effective transfer rate and inference time are assumptions for the calculation.
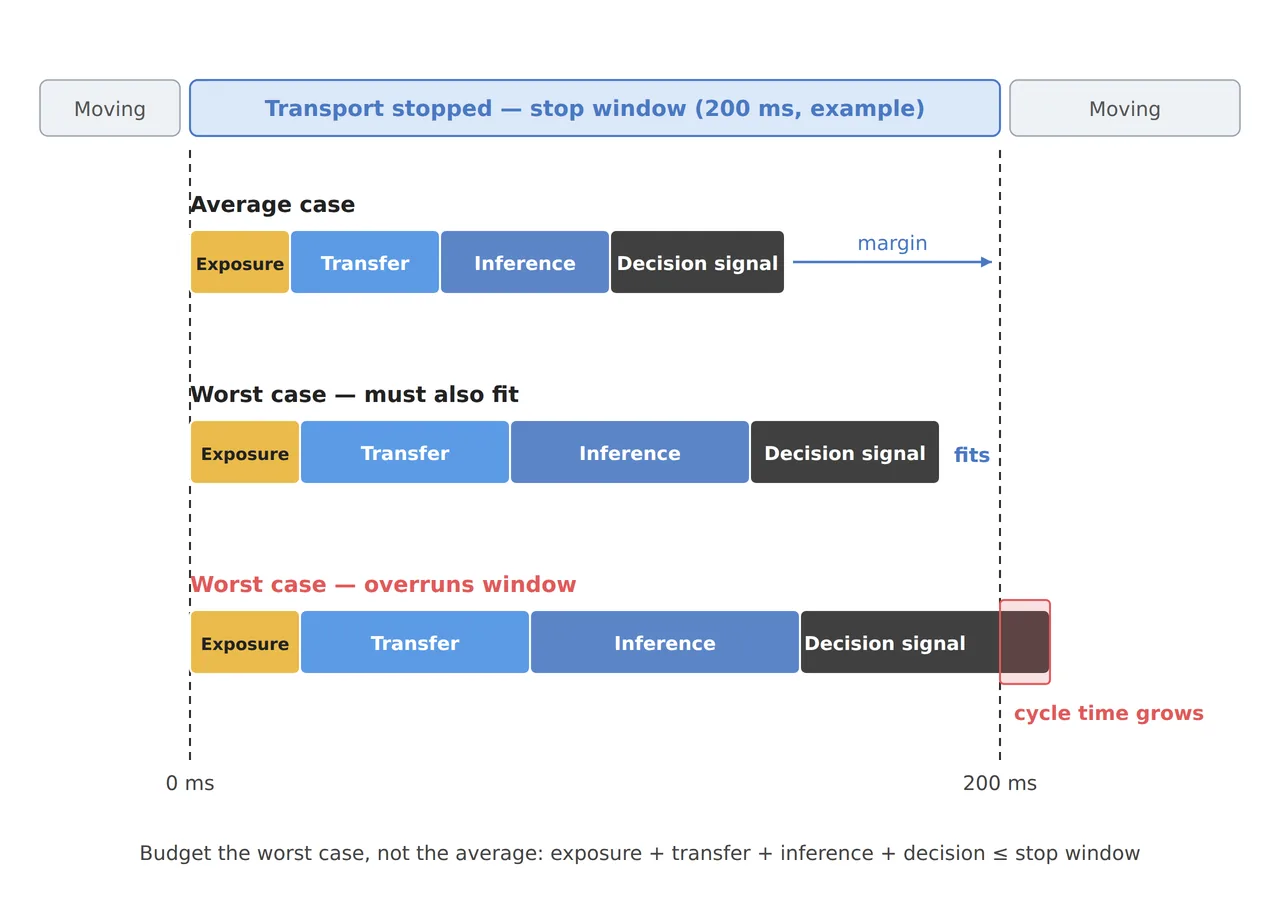
On the average alone, the margin is more than double. Putting in the worst case gives the lower two rows of the figure. With one retransmission the transfer takes 87.2 ms, inference sometimes stretches to 70 ms, and a decision sent as a network message takes 30 ms at worst, for a total of 188.2 ms that fits inside 200 ms with 11.8 ms to spare. With a worst-case inference of 90 ms the total is 208.2 ms, past the window, and transport waits for the 8.2 ms overrun while the cycle time grows.
So I write the stop window budget as the worst-case latency, and I measure that worst case as the maximum in a full day's log. An average over a few hours of commissioning does not catch a tail that shows up a few times a day. How to break down, from the vision side, the latency until the decision signal reaches the PLC continues in the PLC latency breakdown article.
Without a stop, exposure shrinks to 29 μs
If the camera shoots while the part passes without stopping, the calculation changes. Assuming the target passes at 0.5 m per second, the distance moved during exposure has to stay within one 14.7 μm pixel, so exposure is 29.4 μs or less. Getting the same brightness as a 1 ms exposure takes 34 times the instantaneous light, which brings in a strobe8 light fired that much shorter and harder. Light is part of the budget too.
With a stop window, the optical design becomes much simpler. Exposure can stay at 1 ms and the light can run continuously, so whether transport can include a stop window is the first fork in the vision-side design. Whether to stop and for how long is the transport mechanism's decision, so I hand over a table with the numbers for both cases side by side first. The handoff point comes down to the three rows below.
| Item | Value | Condition and basis | In plain words |
|---|---|---|---|
| ① Minimum defect size | Chipping 50 μm = 3.4 px, position tolerance ±100 μm = ±6.8 px | Resolution 14.7 μm/px (2,448 px, 36 mm FOV assumed), edge repeatability 0.1 pixel = 1.47 μm assumed | Chipping spans a little over three pixels; position is measured finer than one pixel |
| ② Optical setup · WD | Low-angle bar light or backlight, coaxial light switched in turn for scratches, WD 184.2 mm with a 35 mm lens | At the same 36 mm FOV, WD is proportional to focal length (25 mm 131.6 mm, 50 mm 263.1 mm) | If the lens hits the mechanism, step back with a longer lens |
| ③ Algorithm parameters | Worst case 188.2 ms inside a 200 ms stop window (assumed), drift threshold against the reference mark, minimum chipping blob 3 px | Average 84.6 ms. A 90 ms worst-case inference makes 208.2 ms, over the window. Shooting in motion needs exposure of 29.4 μs or less | Set the time by the slowest moment of the day |
The number that ties the three rows together is the worst-case latency in ③. The 3.4 pixels in ① and the WD in ② are fixed the moment the camera is chosen, but the 8.2 ms over the window is a tail that appears a few times a day in operation, so commissioning that looks only at averages does not reveal it. That is why the worst case is taken from a full day's log, and whether it fits inside the stop window is written into the acceptance conditions.
Setting the position and time budget of checkpoints along the transport route is the work of a vision engineer on the process automation side, and the person who reads optical calculations and communication latency together takes this seat. In terms of cost, how many ms the stop window grows is a cost that reaches output directly, alongside the camera count, so it is safer to match the vision specs and the transport specs in one table. This article explains technology and is not investment advice. See our Disclaimer.
Field Note
If a camera goes onto this handoff, I run a day-long test that records reference mark drift and latency together. Drift gets one line per wafer, latency is written out split into exposure, transfer, inference and decision signal, and I look separately at the ten records that come closest to the 200 ms stop window. If those ten cluster in a particular time of day, I suspect network load.
Field Checkpoints
Once a day of records is in, turn the handoff point's specs into sentences with the questions below.
- Does the checkpoint sit right after a direction change or a lift ends? (whether it is where the error first becomes visible)
- Does one pixel hold a 50 μm chip across three pixels or more? (3.4 pixels at 14.7 μm/px)
- Is WD secured between the lens and the transport mechanism? (184.2 mm with a 35 mm lens at the same 36 mm FOV)
- Did you write the stop window budget as the worst-case latency over a full day? (average 84.6 ms, worst 188.2 ms)
- When a mirror-like wafer face and a matte carrier share one frame, did you confirm with samples where to set the exposure? (whether you avoid concluding from calculation alone)
- If a section shoots in motion, did you confirm a 29.4 μs exposure and the strobe light to match? (34 times the light of 1 ms)
Frequently Asked Questions
Can a single position camera also catch surface damage?
Position checks depend on edge contrast and surface damage on top-face contrast, so the lighting conditions differ. Doing both with one camera means taking two frames with the lights switched in turn, and adding the second frame's exposure and transfer of 44.6 ms makes the worst-case latency 232.8 ms, past the 200 ms window. In that case look at sending only the region of interest to cut the transfer, or at splitting the job across cameras.
What changes with a faster interface than Gigabit Ethernet?
The worst-case latency gains margin by however much of the 43.6 ms transfer is cut. The tails of inference and the decision signal remain, though, so before changing the interface, look in a full day's log at which segment produces the worst case.
Glossary
- [1] Chipping chipping
A defect where a small piece of the edge has broken away. It resembles a nick on the rim of a glass. ↩ - [2] OHT overhead hoist transport
A transport unit that moves along ceiling rails and lifts carriers to carry them. ↩ - [3] Handoff handoff
The point where a carried item passes from one unit to the next. ↩ - [4] Resolution resolution, μm/px
The width one pixel covers on the target. At 14.7 μm/px, 1 mm is seen as sixty-eight pixels. ↩ - [5] Subpixel subpixel
A calculation that estimates an edge position finer than one pixel. It reads where in the pixel the boundary lies from the brightness change across neighboring pixels. ↩ - [6] WD working distance
The distance from the front of the lens to the surface being inspected. The values here use the thin-lens approximation. ↩ - [7] Cycle time cycle time
The time from handling one item to receiving the next. Latency beyond the stop window adds straight onto the cycle time. ↩ - [8] Strobe strobe
A light that turns on very strongly for a very short moment. It is used to shoot a moving target as if it stood still. ↩
References
- Formulas: resolution = FOV ÷ horizontal pixel count, magnification = sensor width ÷ FOV, WD ≈ f × (1 + 1/m), transfer time = bytes per frame ÷ effective transfer rate, exposure for blur within one pixel = resolution ÷ travel speed
- Related calculations on this site: camera installation space and WD, latency breakdown from trigger to result output
Related reading — The Vision Decision Is Done, So Why Does the PLC Learn It Late? · Why an Average Latency Inside the Deadline Is Not Safe · Edge AI Inference Latency Is Set by the Camera Interface Before the NPU

Noctvision
An engineer who has handled mechanical design and project management for production equipment since 2005. Here I work through the cameras, lenses and lighting that go into equipment with formulas and public data, and record the assumptions and sources alongside the numbers.


You May Also Like
It Worked on the Server, So Why Does Accuracy Drop on the Edge?
Where Do Fine Defects Go When You Shrink to 640 × 640?